Zhenyu Li received the Ph.D. degree in mechanical engineering from Tongji University, Shanghai, China, in 2023. During his doctoral studies, he was affiliated with the Institute of Intelligent Vehicles and the Center for Autonomous Intelligent Unmanned Systems at Tongji University. He was also invited to undertake joint doctoral research at the Department of Computer Science, Technical University of Munich, Germany, and the Department of Computer Science, University of Toronto, Canada. He is currently a faculty member with the Faculty of Mechanical Engineering, Qilu University of Technology (Shandong Academy of Sciences), Jinan, China.
He has published more than 50 research papers in prestigious international journals and top-tier conferences, including IEEE Transactions on Intelligent Transportation Systems, IEEE Transactions on Industrial Informatics, and IEEE Transactions on Artificial Intelligence, as well as CCF-A-ranked international conferences such as CVPR, NeurIPS, and AAAI. His current research interests include autonomous driving, robotic vision and cross-modal localization, embodied intelligence, and cross-modal navigation for autonomous systems operating in complex environments.
Dr. Li has served as a reviewer for several IEEE Transactions journals, including IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI), IEEE Transactions on Mechatronics (TMECH), IEEE Transactions on Industrial Informatics (TII), IEEE Transactions on Intelligent Transportation Systems (TITS), IEEE Transactions on Artificial Intelligence (TAI), and IEEE Transactions on Automation Science and Engineering (TASE). He has also served as a Senior Program Committee (SPC) member or Program Committee (PC) member for several leading international conferences, including CVPR, NeurIPS, ICLR, AAAI, IROS, and ICRA. In 2019, he was a finalist for the Best Paper Award at the IEEE International Conference on Robotics and Biomimetics (ROBIO 2019).
📣 We welcome outstanding and self-motivating undergraduate students to participate in subject competitions, and to jointly carry out research on cutting-edge topics. We also welcome outstanding postgraduate students from both inside and outside the school to collaborate on AI & Robotic research.
Research Topics
- Computer Vision
- Visual Place Recognition
- Cross-Modal Place Recognition
- Robotics
News
 A papers have been accepted by《IEEE Transactions on Intelligent Transportation Systems》 ! well done👏👏👏!!!
- Two papers have been accepted by《NeurIPS 2026》 ! well done👏👏👏!!! Congratulations to Tianyi (本科生)!!!
- Our paper “Hybrid State Space Modeling for Sequence-based Robot Localization Under Challenging Environments” has been accepted by《IEEE Transactions on Automation Science and Engineering》 ! well done👏👏👏!!!
- Our paper “A2GC: Asymmetric Aggregation with Geometric Constraints for Locally Aggregated Descriptors” has been accepted by《CVPR 2026》 ! well done👏👏👏!!!
- Our paper “Vehicle-SceneInteraction: A Text-Driven 3-D Lidar Place Recognition Method for Autonomous Driving” has been accepted by《IEEE Transactions on Intelligent Transportation Systems》 ! well done👏👏👏!!! Congratulations to Tianyi (本科生)!!!
- Our paper “Seeing Through the Rain: Multi-Stage Attention with Depth-Guided Restoration for Robust Localization” has been accepted by《IEEE Transactions on Industrial Informatics》 ! well done👏👏👏!!!
Team
coming soon …
Publications
(2026 published papers)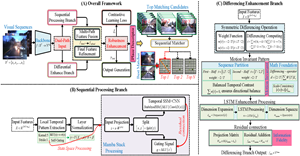
Hybrid State Space Modeling for Sequence-based Robot Localization Under Challenging Environments, IEEE Transactions on Automation Science and Engineering (TASE).

Zhenyu Li*, Tianyi Shang
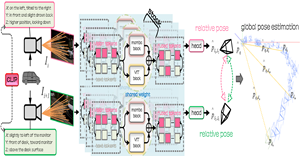
Language-Guided Hybrid Sequence Modeling for Vehicle Relocalization via Pose Estimation, IEEE Transactions on Intelligent Transportation Systems (TITS).
Zhenyu Li, Tianyi Shang*, Pengjie Xu
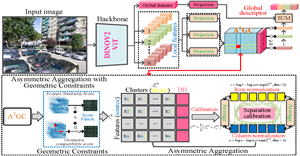
A2GC: Asymmetric Aggregation with Geometric Constraints for Locally Aggregated Descriptors, The 2026 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR).
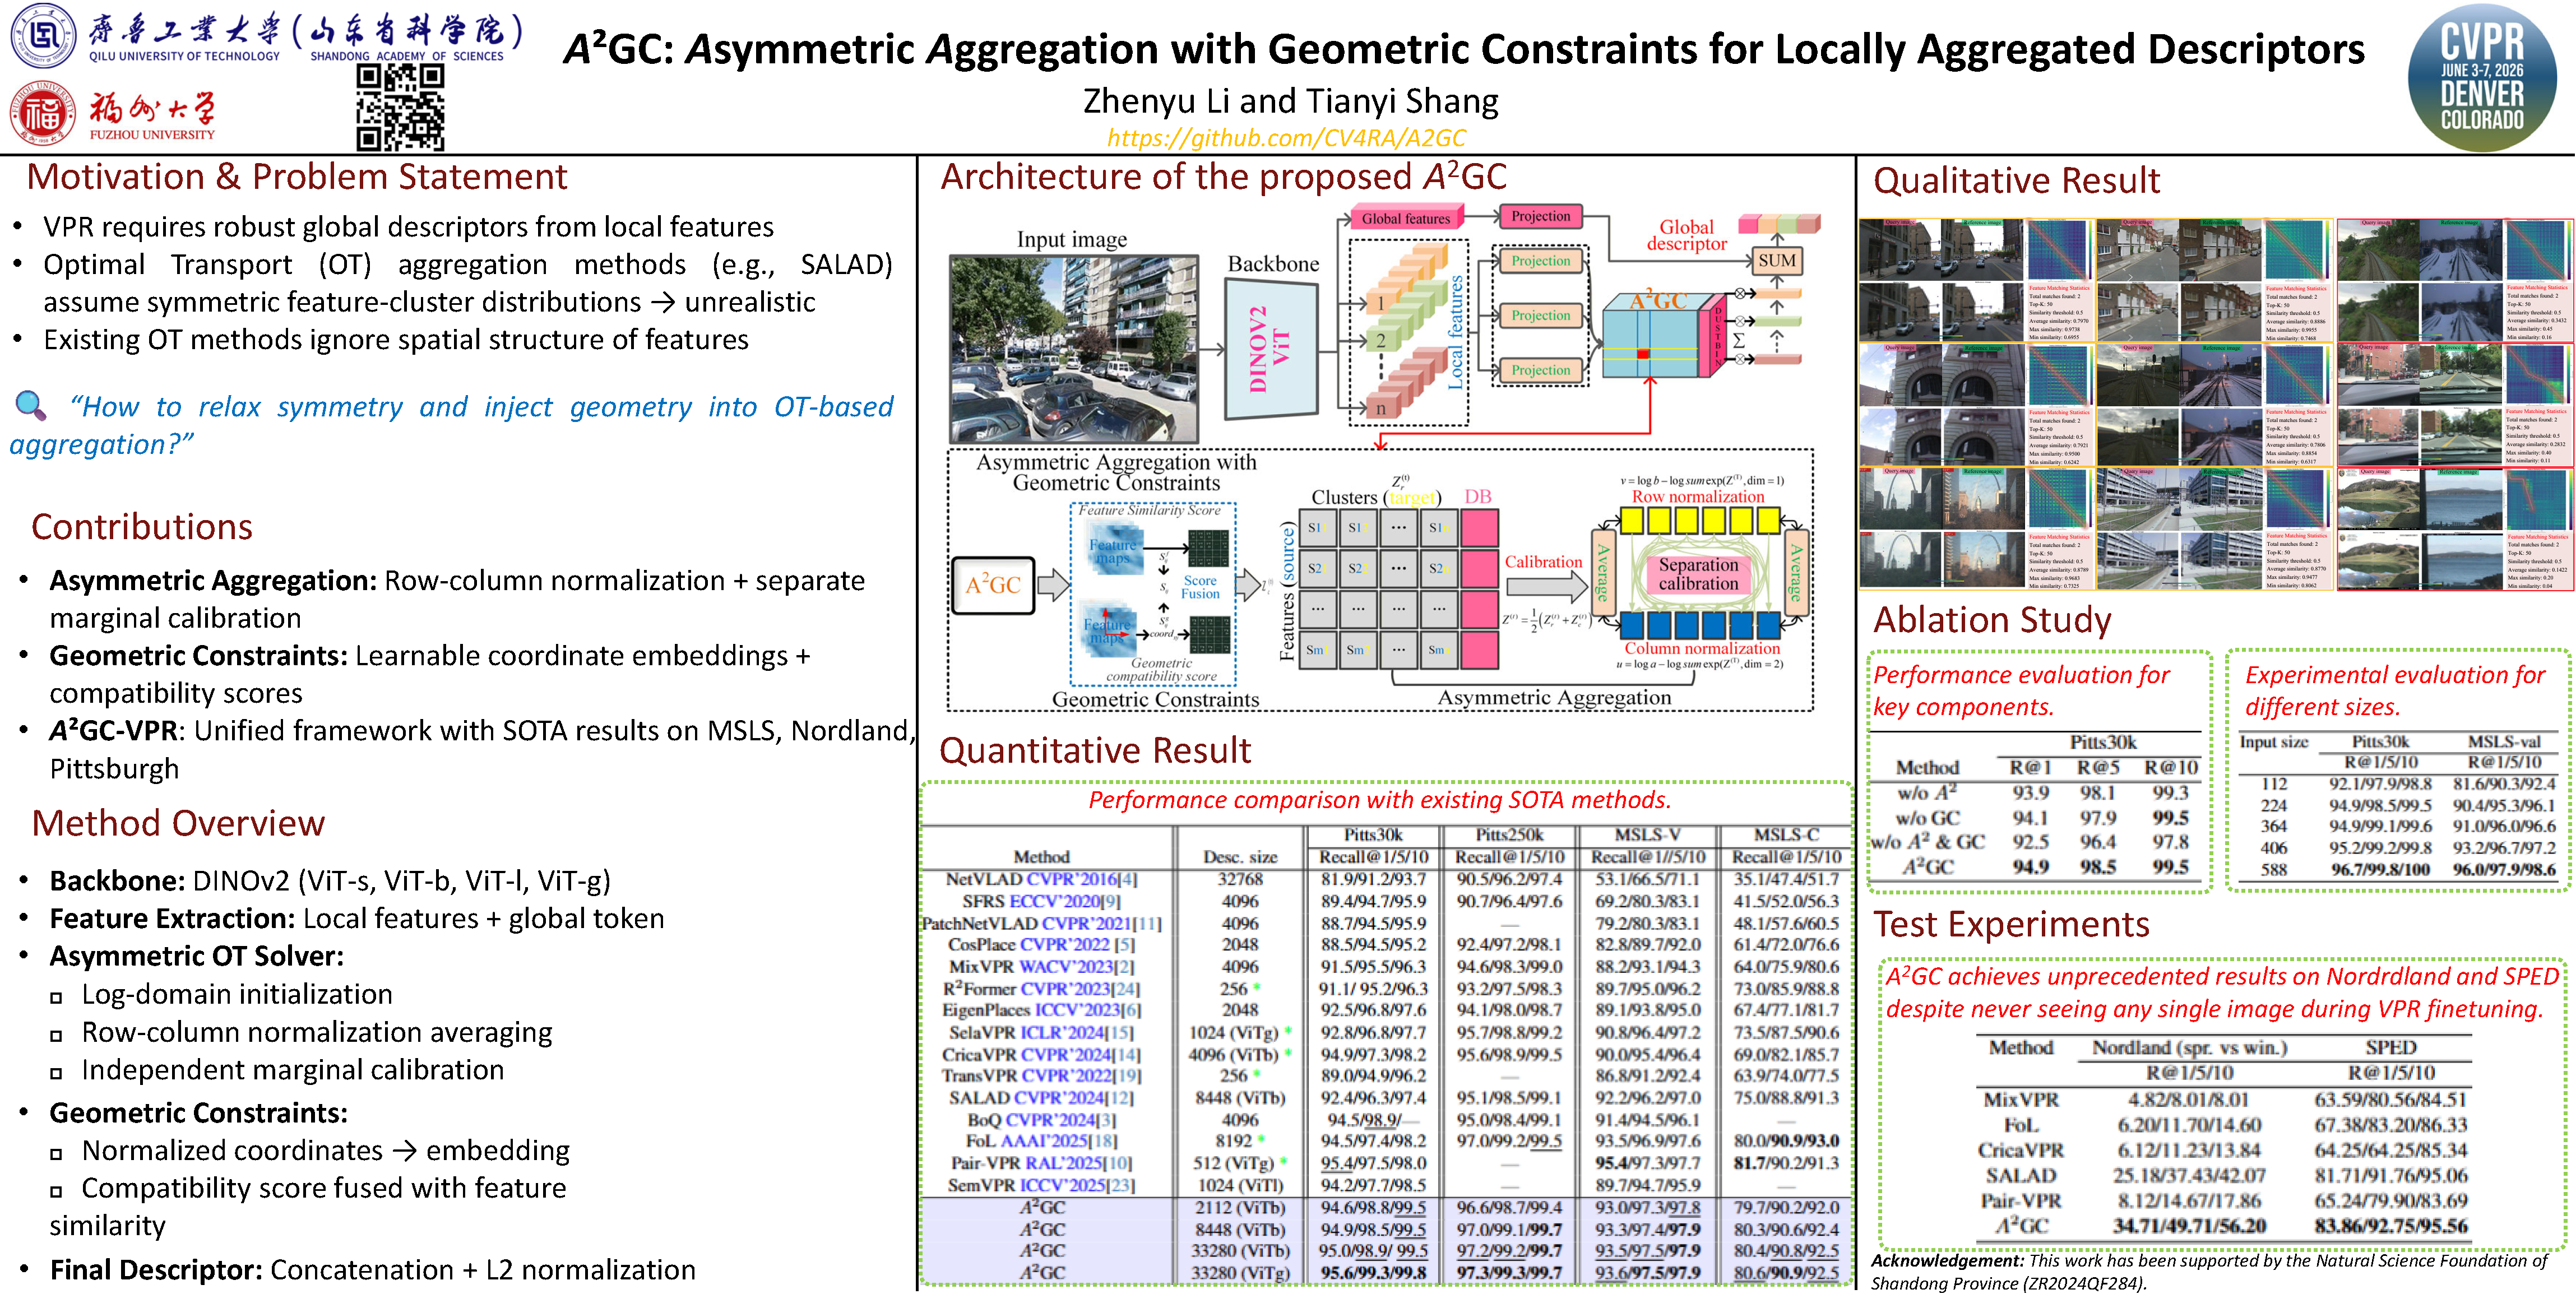


Zhenyu Li*, Tianyi Shang
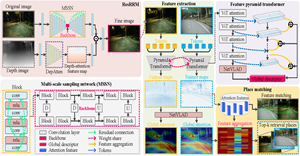
Seeing Through the Rain: Multistage Attention With Depth-Guided Restoration for Robust Localization, IEEE Transactions on Industrial Informatics (TII).
Zhenyu Li*, Tianyi Shang, Jinwei Qiao, Pengbo Liu, Zhaojun Deng
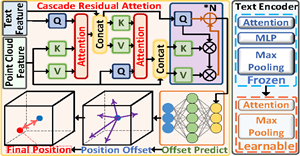
Vehicle-Scene Interaction: A Text-Driven 3-D Lidar Place Recognition Method for Autonomous Driving, IEEE Transactions on Intelligent Transportation Systems (TITS).
Tianyi Shang, Zhenyu Li*, Pengjie Xu, Zhaojun Deng
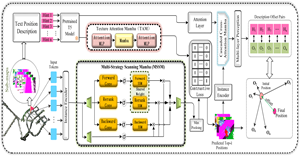
MambaPlace: Text-to-Point-Cloud Cross-Modal Place Recognition with Attention Mamba Mechanisms, 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
Tianyi Shang, Zhenyu Li*, Pengjie Xu, Jinwei Qiao
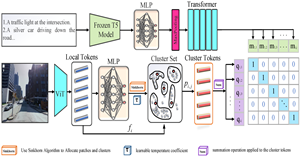
Bridging Text and Vision: A Multi-View Text-Vision Registration Approach for Cross-Modal Place Recognition, 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS).
Tianyi Shang, Zhenyu Li*, Pengjie Xu, Jinwei Qiao, Gang Chen, Zihan Ruan, Weijun Hu
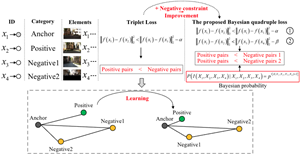
Quadruplet-attention transformer for scale-invariant robot placerecognition, Expert Systems with Applications (ESWA).
Zhenyu Li*, Pengjie Xu
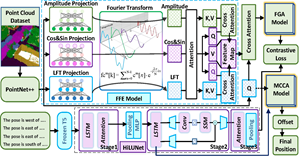
FourierPlace: A Vision-Language Localization Framework Based on Frequency Domain Representations, IEEE Robotics and Automation Letters (RAL).
Tianyi Shang, Zhenyu Li*, Shuaishuai Lu, Pengjie Xu
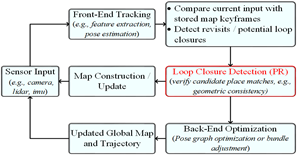
Place Recognition Meet Multiple Modalitie: A Comprehensive Review, Current Challenges and Future Directions, Artificial Intelligence Review.
Zhenyu Li*, Tianyi Shang, Pengjie Xu, Zhaojun Deng
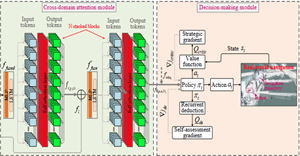
Multi-Modal Attention Perception for Intelligent Vehicle Navigation using Deep Reinforcement Learning, IEEE Transactions on Intelligent Transportation Systems (TITS).
Zhenyu Li*, Tianyi Shang, Pengjie Xu
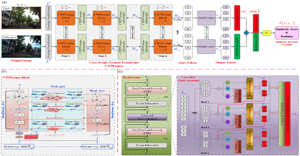
CWPFormer: Towards High-performance Visual Place Recognition for Robot with Cross-weight Attention Learning, IEEE Transactions on Artificial Intelligence (TAI).
Zhenyu Li*, Pengjie Xu, Tianyi Shang
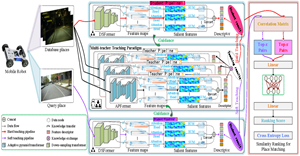
Feature-Level Knowledge Distillation for Place Recognition Based on Soft-Hard Labels Teaching Paradigm, IEEE Transactions on Intelligent Transportation Systems (TITS).
Zhenyu Li*, Pengjie Xu, henbiao Dong, Ruirui Zhang, Zhaojun Deng
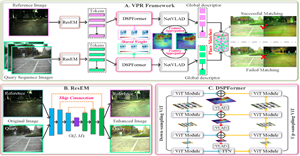
Toward robust visual place recognition for mobile robots with an end-to-end dark-enhanced net, IEEE Transactions on Industrial Informatics (TII).
Zhenyu Li*, Pengjie Xu, henbiao Dong, Ruirui Zhang, Zhaojun Deng